George
Hartt
Robotics engineer. I design the mechanics, lay out the circuit boards and write the firmware and software that make my robots move.
Projects
-
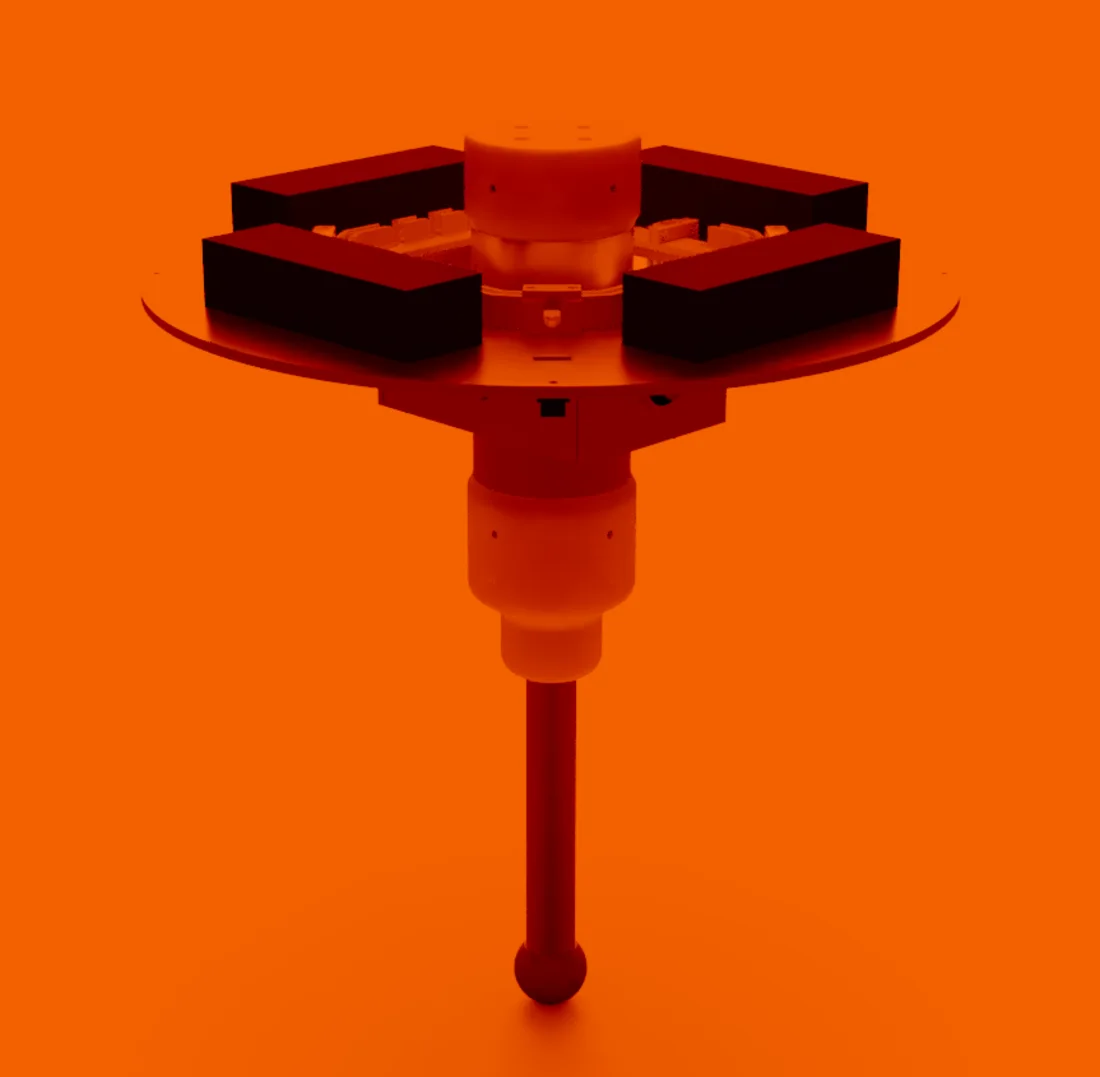
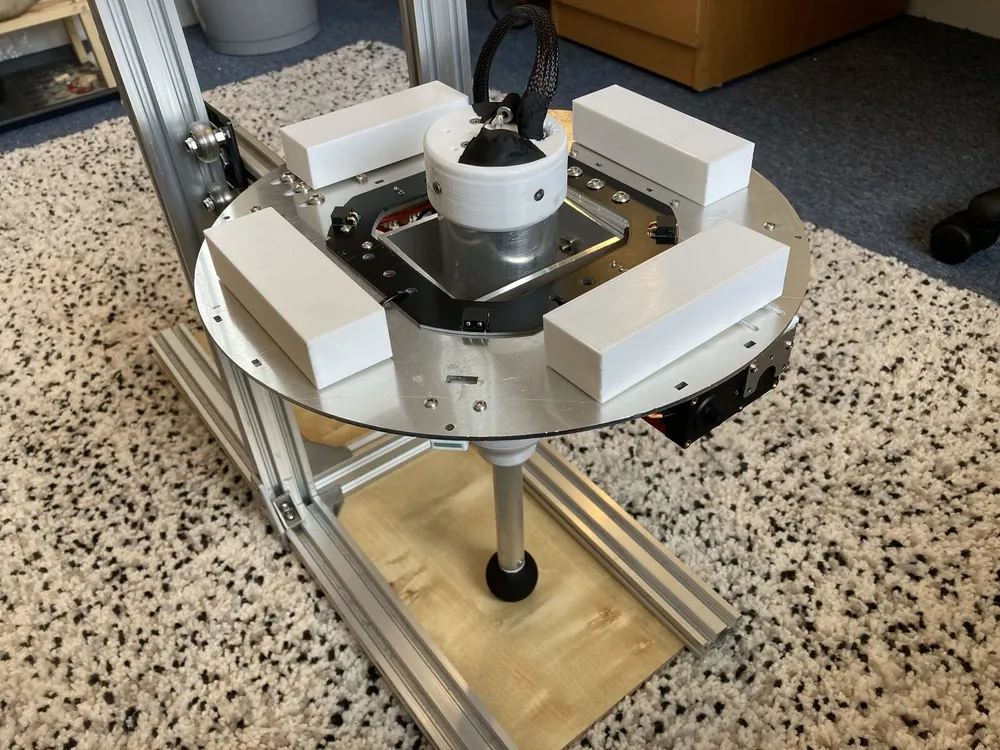
Monopod
An untethered one-legged jumping robot
A hopper inspired by Marc Raibert's, driven by a voice coil actuator I built from scratch. One leg, no tether, and it jumps more than once.
-
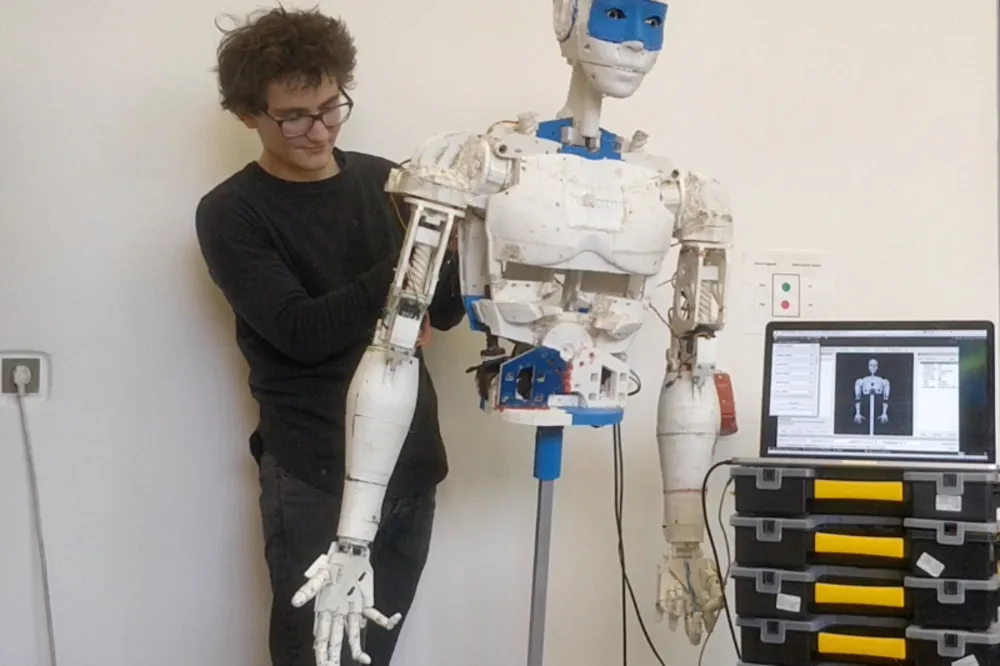
InMoov
An open-source humanoid robot
During an internship at the Czech Technical University in Prague, I printed over 200 parts, fitted the motors and encoders, and added control and visualisation in ROS.
-
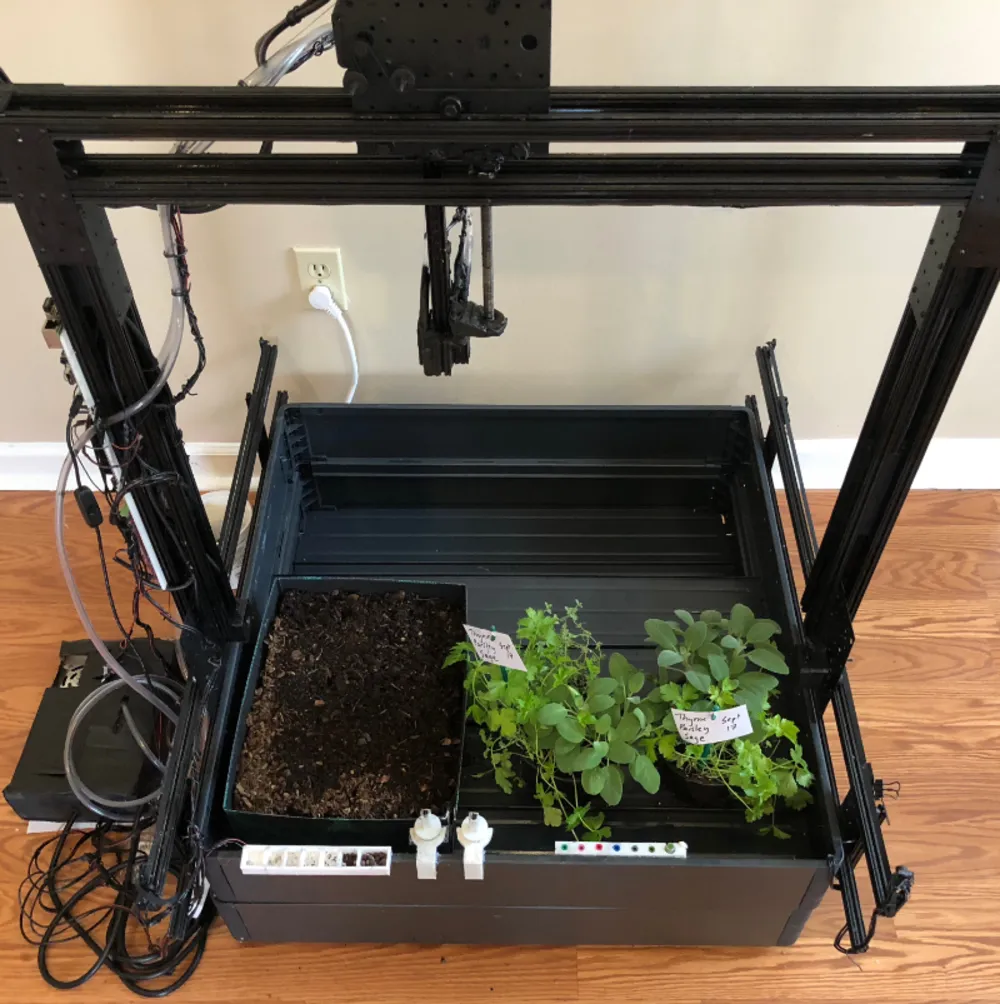
Autonomous Growing Unit
A robot that looks after a small garden
An Android app sends instructions to a Raspberry Pi, which drives an Arduino Mega controlling the hardware. I designed the electronics in Eagle and the frame in Inventor.
-
Spotify to MP3
Download your Spotify playlists to an old iPod
It reads your playlists through the Spotify API, finds the best-quality match for each song on YouTube, and saves it to disk as an MP3.
-
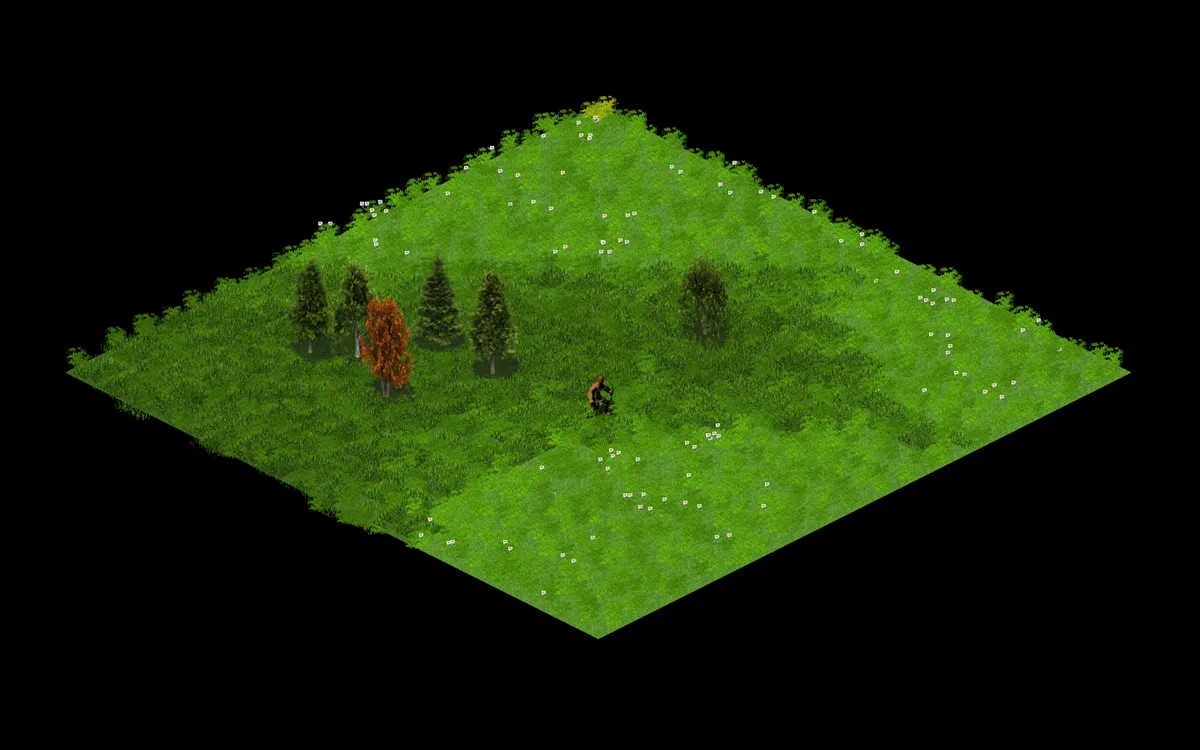
Isometric Survival Game
A game written from scratch in plain Java
No game engine: I wrote the physics, the rendering engine and the world generator myself, with chunk caching to keep it running smoothly.
About
I love multidisciplinary robotics projects that pull together software, hardware and electronics. I use the same skills in freelance work, full-time roles and teaching robotics in schools around London.
Software
From assembly on 8051 microcontrollers to gaits evolved with a genetic algorithm in a simulator.
Hardware
3D printing, CNC machining, CAD, PCB design and microcontrollers: everything it takes to get an idea off the screen.
Languages
- Python
- C++
- Embedded C
- Assembly
- Java and Android SDK
Tools
- Linux, ROS and git
- Jupyter and pandas
- CAD and ECAD
- Microcontrollers and SBCs
- 3D printing
Away from the desk
- Camping
- Archery
- Parkour
- Dance
- Rock climbing